A class to programmatically represent a very basic vehicle with two motors. More...
#include <SimpleCar.hpp>
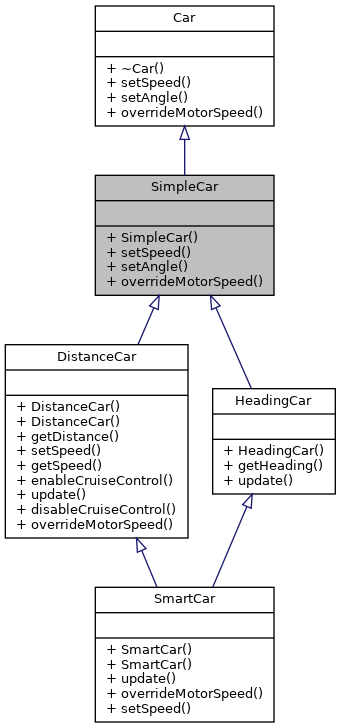
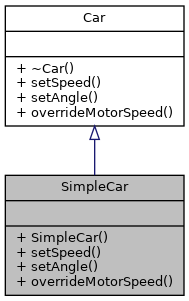
Public Member Functions | |
| SimpleCar (Control &control) | |
| Constructs a simple car. | |
| void | setSpeed (float speed) override |
| Sets the car's driving speed as a percentage of the motors total speed where the sign indicates direction. | |
| void | setAngle (int angle) override |
| Set the car's driving angle. | |
| void | overrideMotorSpeed (int firstMotorSpeed, int secondMotorSpeed) override |
| Set the motor speed individually as a percentage of the motors` total power. | |
 Public Member Functions inherited from Car | |
| virtual | ~Car ()=default |
Detailed Description
A class to programmatically represent a very basic vehicle with two motors.
Definition at line 10 of file SimpleCar.hpp.
Constructor & Destructor Documentation
◆ SimpleCar()
|
explicit |
Constructs a simple car.
- Parameters
-
control The car's control
Example:
Definition at line 7 of file SimpleCar.cpp.
Member Function Documentation
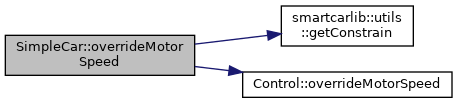
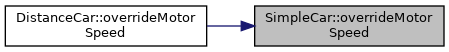
◆ overrideMotorSpeed()
|
overridevirtual |
Set the motor speed individually as a percentage of the motors` total power.
Use this with caution.
- Parameters
-
firstMotorSpeed The speed of the motor passed as first argument argument to the car's control class [-100, 100] secondMotorSpeed The speed of the motor passed as second argument argument to the car's control class [-100, 100]
Example:
Implements Car.
Reimplemented in SmartCar.
Definition at line 22 of file SimpleCar.cpp.
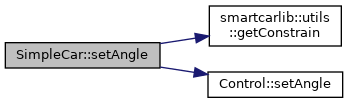
◆ setAngle()
|
overridevirtual |
Set the car's driving angle.
- Parameters
-
angle The car's angle in degrees [-90, 90]
Example:
Implements Car.
Definition at line 17 of file SimpleCar.cpp.
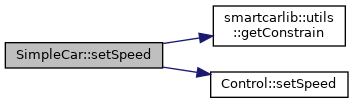
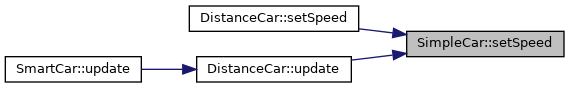
◆ setSpeed()
|
overridevirtual |
Sets the car's driving speed as a percentage of the motors total speed where the sign indicates direction.
- Parameters
-
speed The car's speed [-100, 100]
Example:
Implements Car.
Reimplemented in SmartCar.
Definition at line 12 of file SimpleCar.cpp.
The documentation for this class was generated from the following files:
- src/car/simple/SimpleCar.hpp
- src/car/simple/SimpleCar.cpp